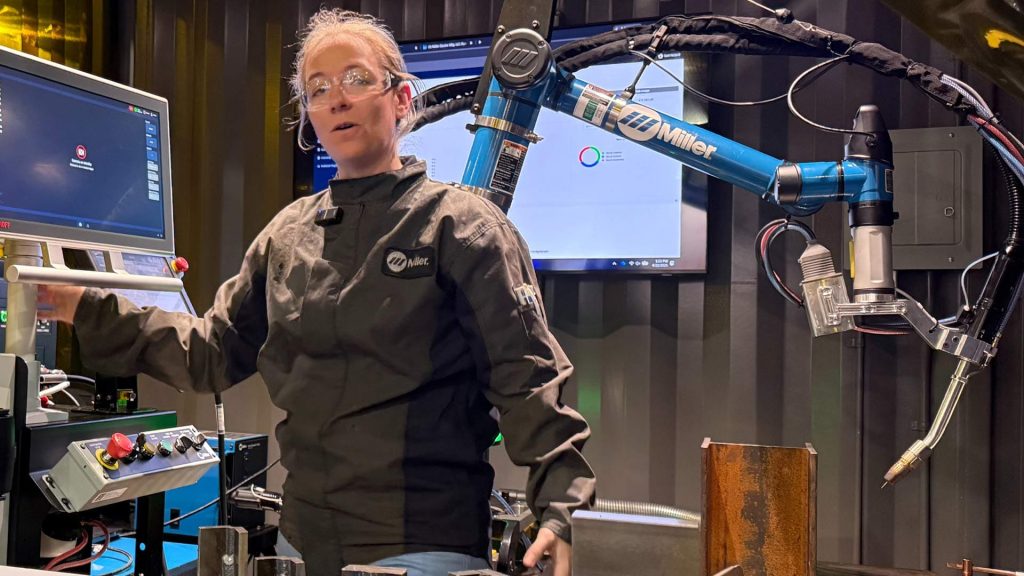
In robotic welding, the discussion about programming methods is often framed as offline programming (OLP) software versus pendant-based programming, as if one must choose one over the other. In real workcells, the distinction is not so absolute. Both methods are regularly used side by side, and some systems deliberately combine them.
Make no mistake, for some tasks, OLP software is the right tool, but for others, a pendant is faster and more practical. In practice, the balance between the two often shifts as part size, weld length and production complexity increase.

This article explores where OLP adds value, where pendant programming is the better choice, how they work together in practice and why not all OLP and digital twin systems are the same.
Where OLP shines
There are applications where pendant programming is inefficient and impractical. Large fabrications such as ship sections, truck bodies, long beams and structural frames involve weld seams that can run for meters, often in positions that are difficult or unsafe to access. In some cases, accessing the weld path requires operators to physically climb around large rotating structures. The fact that pendants are typically physically connected to the controller only adds to the awkwardness and the potential safety risks.
Programming these jobs entirely on a pendant requires manually teaching hundreds or thousands of points and spending extended periods at the physical cell, often testing welds at realistic speeds simply to confirm reachability and avoid collisions.
In practical terms, this can mean validating hundreds of meters of weld at real welding speeds. At typical welding rates of around 50 cm per min., even a single verification pass can take hours, making purely pendant-based workflows increasingly impractical as scale grows.

At a certain point, factors such as weld length, access constraints and validation time make manual teaching impractical. For example, programming a long truck chassis with multiple weld seams on both sides can require hundreds of points and repeated repositioning if done on a pendant. The same complex weld strategies can be defined and validated in minutes from a 3-D CAD model using OLP software because the software enables weld paths to be defined directly on the part’s geometry rather than on the physical part.
OLP software also enables factors like reachability, robot configurations and collision avoidance to be validated in simulation before any code is run on the workcell. This transforms a slow, physical, trial-and-error process into a fast, iterative, digital one. It also enables levels of planning, validation and complexity that are difficult to achieve directly on the shop floor. As weld lengths increase and part geometries become more complex, the advantages of OLP become more pronounced.
Accurate production
Keep in mind that effective OLP relies on how closely the real part matches the CAD model. Automated welding, particularly laser welding, is especially sensitive to joint geometry and gaps. If parts are poorly cut, bent or fixtured, the robot will follow a path that no longer corresponds to the real joint.
To avoid the digital twin becoming a rough approximation of the real part, it is crucial to ensure that upstream manufacturing is controlled and repeatable. When that is the case, the simulated geometry aligns more closely with reality, and OLP software can provide accurate paths with minimal adjustment.
For example, in a well-controlled laser cut and bent assembly, a weld programmed offline can run with minimal adjustment, whereas the same program on poorly prepared parts requires constant correction or seam tracking to stay on the joint.

Modern robot and CNC controllers support complex motion capabilities, including advanced path definitions that are time-consuming to code point by point on a pendant. OLP software makes these capabilities usable in practice by enabling complex paths such as coordinated multi-axis motion, circular welds and parametric trajectories to be defined and executed reliably.
Capable OLP software can automatically generate accurate toolpaths, estimate cycle times and enable rapid transitions from CAD to executable programs. In this way, OLP software is more than a programming tool; it is a planning and decision-making tool that supports quoting, feasibility analysis and ongoing production decisions.
In high-mix environments, this means more accurate quoting and production planning because simulated cycle times can closely match real execution, but only when the system is properly calibrated. As job size and variability increase, manual estimation and validation quickly become impractical.
Understanding the software
OLP and digital twin systems vary significantly in capability. Some platforms, including RoboDK, offer integrated calibration tools while others rely on external workflows or do not support calibration at all. Crucially, robot calibration helps ensure that the mathematical model of the robot aligns with its actual kinematics. OLP software that provides robot calibration produces more reliable results and requires less manual correction.
Meanwhile, some OLP tools are tightly integrated with a single robot brand and offer deep access to that manufacturer’s controller features. Other OLP tools are designed to support multiple robot brands within a single environment, which is more suitable for facilities with mixed fleets and helps avoid vendor lock-in.
Integration with measurement and tracking systems is another practical differentiator. In a production cell, the digital twin does not exist in isolation but interacts with metrology systems, vision-based alignment tools and seam tracking devices. An OLP system that can exchange data with these systems maintains alignment between the digital and physical cell over time and reduces the need for additional compensation mechanisms.
OLP software platforms also differ in how they interact with real robots. Some generate code offline and rely on file transfer while others support direct communication and online control. The latter can enable faster iteration and interactive adjustment, although not all environments require or permit this.
Workflow flexibility also varies with some OLP software platforms offering APIs and scripting capabilities for integrators while others focus on guided interfaces for operators. The most effective platforms tend to support both. For example, platforms like RoboDK combine graphical workflows for operators with APIs for integrators building custom automation pipelines.
Pendant-based perks
For simple applications, pendant programming remains an efficient approach. A straightforward part such as a bracket, enclosure or small frame with short, accessible welds can often be programmed directly on a pendant in a short time by an experienced operator.
In such cases, introducing OLP adds setup steps that do not meaningfully improve the outcome and can even slow down deployment. For example, a simple bracket with three short welds can typically be programmed, tested and running in under an hour directly on a pendant whereas setting up the same job in OLP software could take longer than the welding cycle justifies.
Pendant programming also plays a central role in tasks that are closely tied to the controller. Safety functions, basic I/O logic and service routines such as torch cleaning or homing are often easier to implement and verify directly on the robot – although this can vary depending on the OLP software.
Combining processes
Many production systems use OLP and pendant programming, although the balance typically shifts toward OLP as application complexity increases and more advanced capabilities are required.
In a typical scenario, a pendant is used to handle startup and shutdown and to coordinate I/O and safety logic.

OLP-generated code is then used for the detailed weld paths, particularly where the geometry is complex or the welds are long. Additional routines that require flexibility or direct control are typically coded via pendant.
In practice, OLP software is used to define geometry, generate and validate paths, and estimate performance while the pendant remains the main interface for control logic, safety and real-world adjustments. Integrators typically work more in the OLP environment while operators interact with a combination of guided OLP workflows and the pendant interface.

The limits of simulation
Even with robot calibration, digital twin and OLP software will not replace the need to weld real parts because welding quality depends on physical factors such as heat input, distortion and material behavior. Moreover, factors such as grounding location, electrical resistance across large parts and arc stability can also influence weld quality in ways that are difficult to predict in simulation and must be validated on real hardware.
These factors are most effectively addressed through real-world testing and adjustment. For example, a weld that appears correct in simulation may still produce distortion or poor penetration on the real part due to heat input and material variation, requiring subtle parameter changes or path adjustments after initial trials.
In practice, OLP software rarely produces a production-ready welding program on the first attempt. Teams typically generate an initial program offline, validate it on real parts and iterate based on physical effects such as heat input, distortion, arc behavior and grounding conditions that are not captured in simulation.
This iterative process is essential. OLP reduces the number of iterations and the associated risk, but it does not completely eliminate them.
Some OLP and digital twin systems support remote interaction with robots, including the ability to stream commands over a network. This can be useful for testing and centralized monitoring, but it does not change the fundamentals of safety. Networked control cannot replace hardware-based safety systems, and emergency stops and safety logic must remain within the workcell and the controller. Remote capabilities can extend flexibility, but they operate within the constraints of established safety principles.
OLP and digital twins are essential tools for applications involving large, complex welds and high-mix production with OLP becoming essential beyond a certain scale and complexity. Meanwhile, pendant programming remains the fastest and most practical option for many small tasks and is almost indispensable for controller-level functions.
For overall success, think less in terms of choosing one over the other and more in terms of recognizing where each approach reaches its practical limits.
Offline programming technology evolves at a rapid pace. Get the full story in our archive.